####
About
Hi there! I am a 3B Mechatronics Engineering student at the University of Waterloo. I have a strong passion for robotics, circuits and electronics, and computer vision.
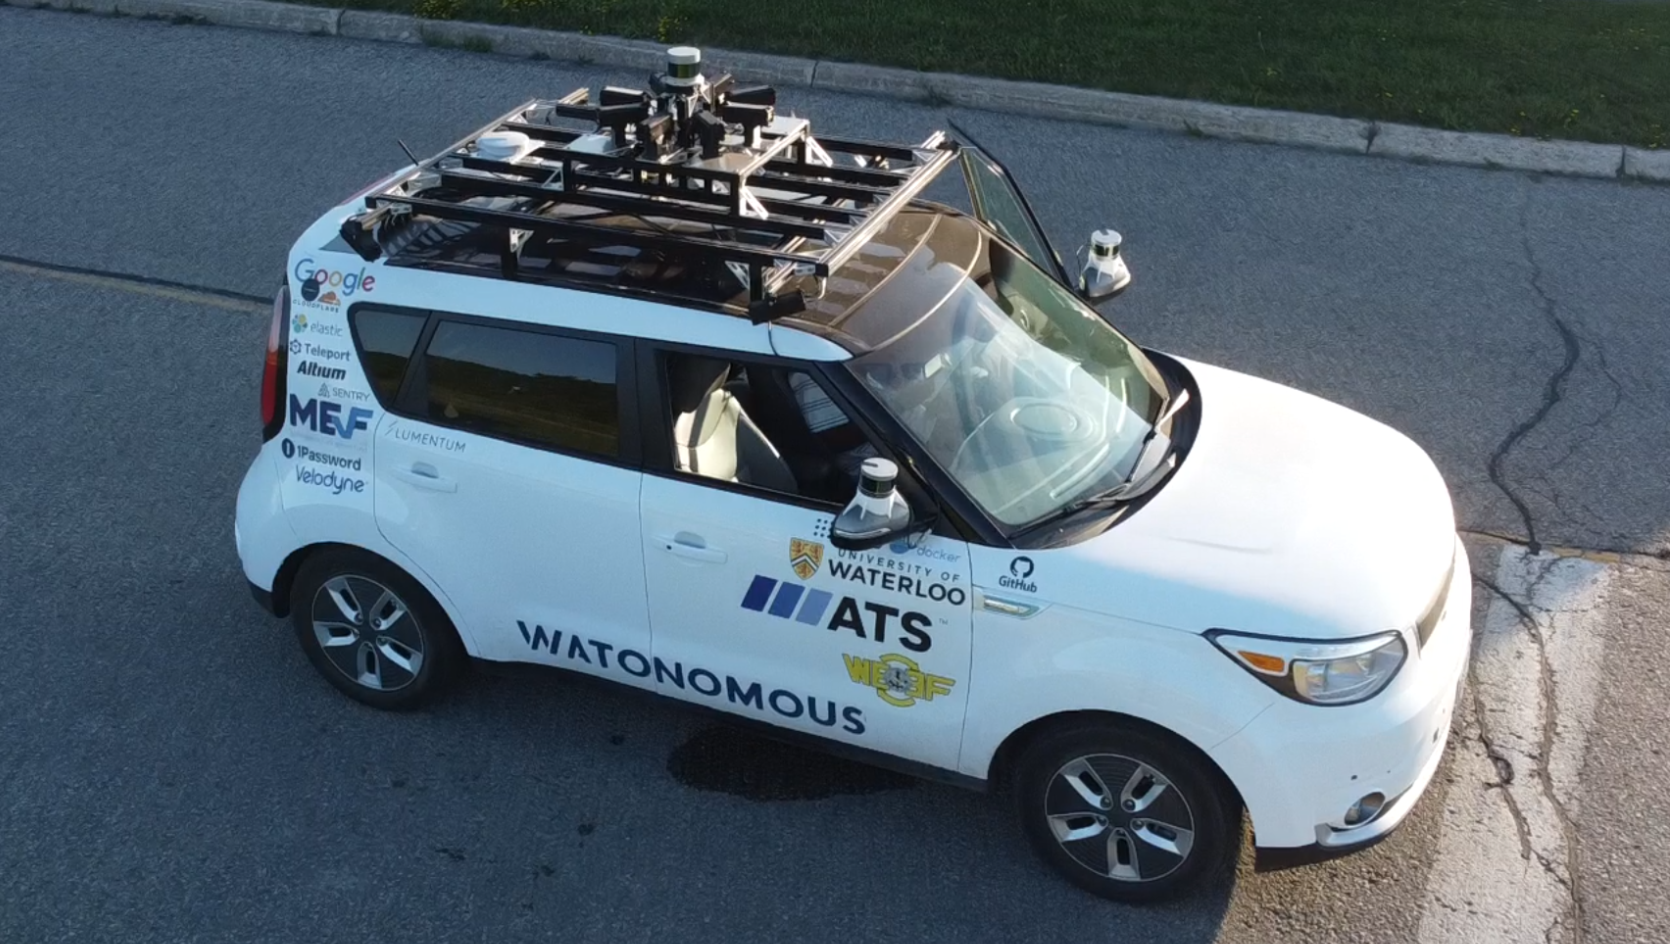
Currently, I am the Perception Team Lead for the Autonomous Vehicle (EVE) on WATonomous, a student design team at the forefront of autonomous robotics technology. In the past, I have been the Autonomy Project Manager on the Waterloo Aerial Robotics Group (WARG), working on making drones self-flying.
I have worked on a variety of projects ranging from robots using compute boards such as NVIDIA Jetsons, to embedded firmware projects using STM32s. I have also developed videos games using Unreal Engine and web applications using React. You can see some of my other projects in the projects section.
I am seeking a co-op (internship) for 4-8 months starting January 2027.
####

|
|
####
Hardware
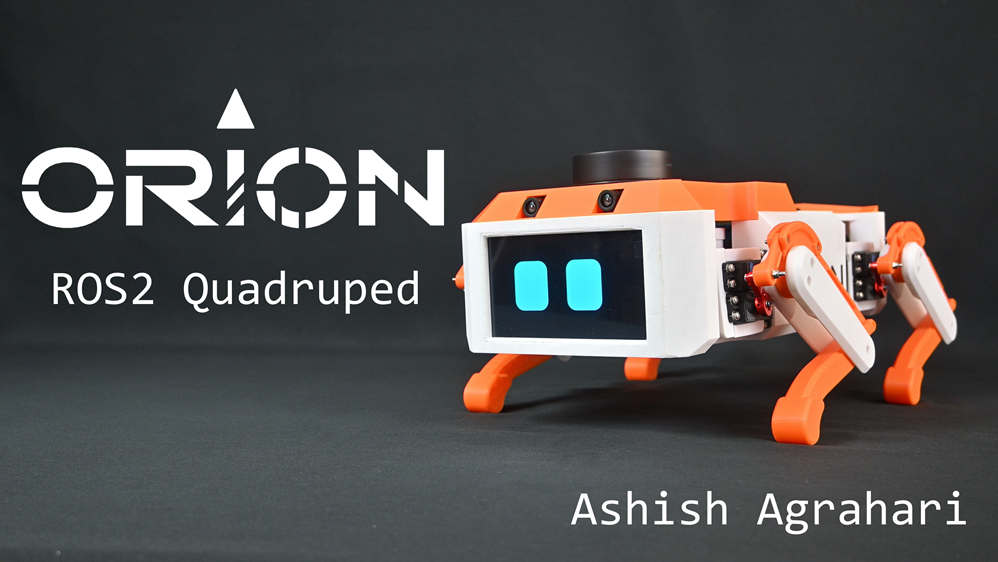
I have worked on several robotics projects, for example a ROS2 & RTOS-driven quadruped robot, and a robotic arm that mimics a user's arm gestures with the aim of helping people with disabilities.
Software
I have also worked on various software-only projects, for instance a messaging app using React Native and Firebase, and a racing video game with networking and multiplayer logic combined with realistic physics.
Academics
Relevant courses: Data Structures and Algorithms, Microprocessor Systems, RTOS, Circuits, Digital Logic, and Sensors and Instrumentation.
Past Employment
Below is my employment history, in reverse chronological order.
VR Software Developer
Vireo Interfaces
May 2026 - Aug. 2026
- Developed in-house 3D reconstruction pipeline via COLMAP, 3DGS, and Docker, for digital-twin and site-capture workflows
- Implemented photorealistic interior design VR platform in Unity, C#, streamlining dynamic customization, eliminating manual validation workflows, and automating report generation reducing configuration errors by 90%
- Prototyped force-feedback system leveraging sensor fusion of IMUs, Meta Quest 3, and vision-based tracking to improve immersion and perceived motion in virtual reality environments
Computer Vision Software Developer
Miovision
Sep. 2025 - Dec. 2025
- Owned end-to-end feature of segmentation network for detecting poor-visibility regions in traffic video streams, using Python, PyTorch, OpenCV, and TensorBoard, enhancing downstream traffic flow management systems
- Improved model performance 32% in Precision and Recall by conducting root-cause analysis, addressing class imbalance, and implementing a self-training pipeline through pseudo-labelling, mitigating effects of low-quality annotations
- Productized use of model, resolving latent integration issues in C++ and TypeScript codebases across multiple teams, averting weeks of potential debugging and production delays
- Worked closely with customers for beta rollout and model deployment on remote NVIDIA Jetsons in the field
- Unblocked integration of 3D LiDAR, supporting future semantic segmentation and perception tasks in ROS2


Computer Vision Software Developer
Miovision
Jan. 2025 - Apr. 2025
- Built computer vision pipeline to automate data collection and annotation of poor-visibility conditions in traffic video streams using Voxel51, S3, and PostgreSQL, saving 15 engineering hours/week and increasing dataset coverage by 75%
- Fine-tuned YOLOv11 model for pedestrian detection using transfer learning, applying data augmentation to improve F1-score by 19% compared to in-house model, using Amazon EC2 and SageMaker
- Integrated state-of-the-art multi-object tracking algorithm for continuous detections of occluded vehicles
HMI Software Developer
Ford Motor Company
May 2024 - Aug. 2024
- Developed customer-facing Android in-car entertainment system using Linux, MVVM, and Fragment Lifecycle
- Created reusable UI modules using Kotlin, Java, and XML to provide a standardized implementation across codebase
- Improved animation efficiency by 23% using Android Studio debugging tools, resulting in a user-friendly experience

Projects
Below are the projects that I have created, or co-created, over the past few years. Click the link icon on each to read more about the project.
- All
- Robotics
- Software
- Unreal Engine
- CAD
- Android/Web